What do about 20 guys studying Aerospace Technology have in common? They all love rockets and building cool stuff.
That’s the reason why WüSpace exists and the S²OUTH project was founded. We are building a telemetry Handler for the N₂ORTH Rocket from HyEnd. The whole project started three years ago and we are now in the third iteration of the system. And let me tell you, it’s awesome. Every day we meet to develop, program, solder and to hang out together. So I want to show you a small part of our work.
I’m talking about T-Rex (Tracking Rocket EXperiment). Building a rocket is a huge amount of work. So naturally you want to see how it flies. Not only for our own entertainment, but also for after flight analysis and triangulating the position. T-Rex has come a long way. At first it was only visual based. It had two cameras. One for tracking and the other one to film the flight.
But when HyEnd asked us to built their Telemetry system, we had a little problem. The mission of N₂ORTH is to cross the Kármán-Line. So it would be nice to have footage when this happens. But with visual tracking this would not be possible. So we had to redesign the system.
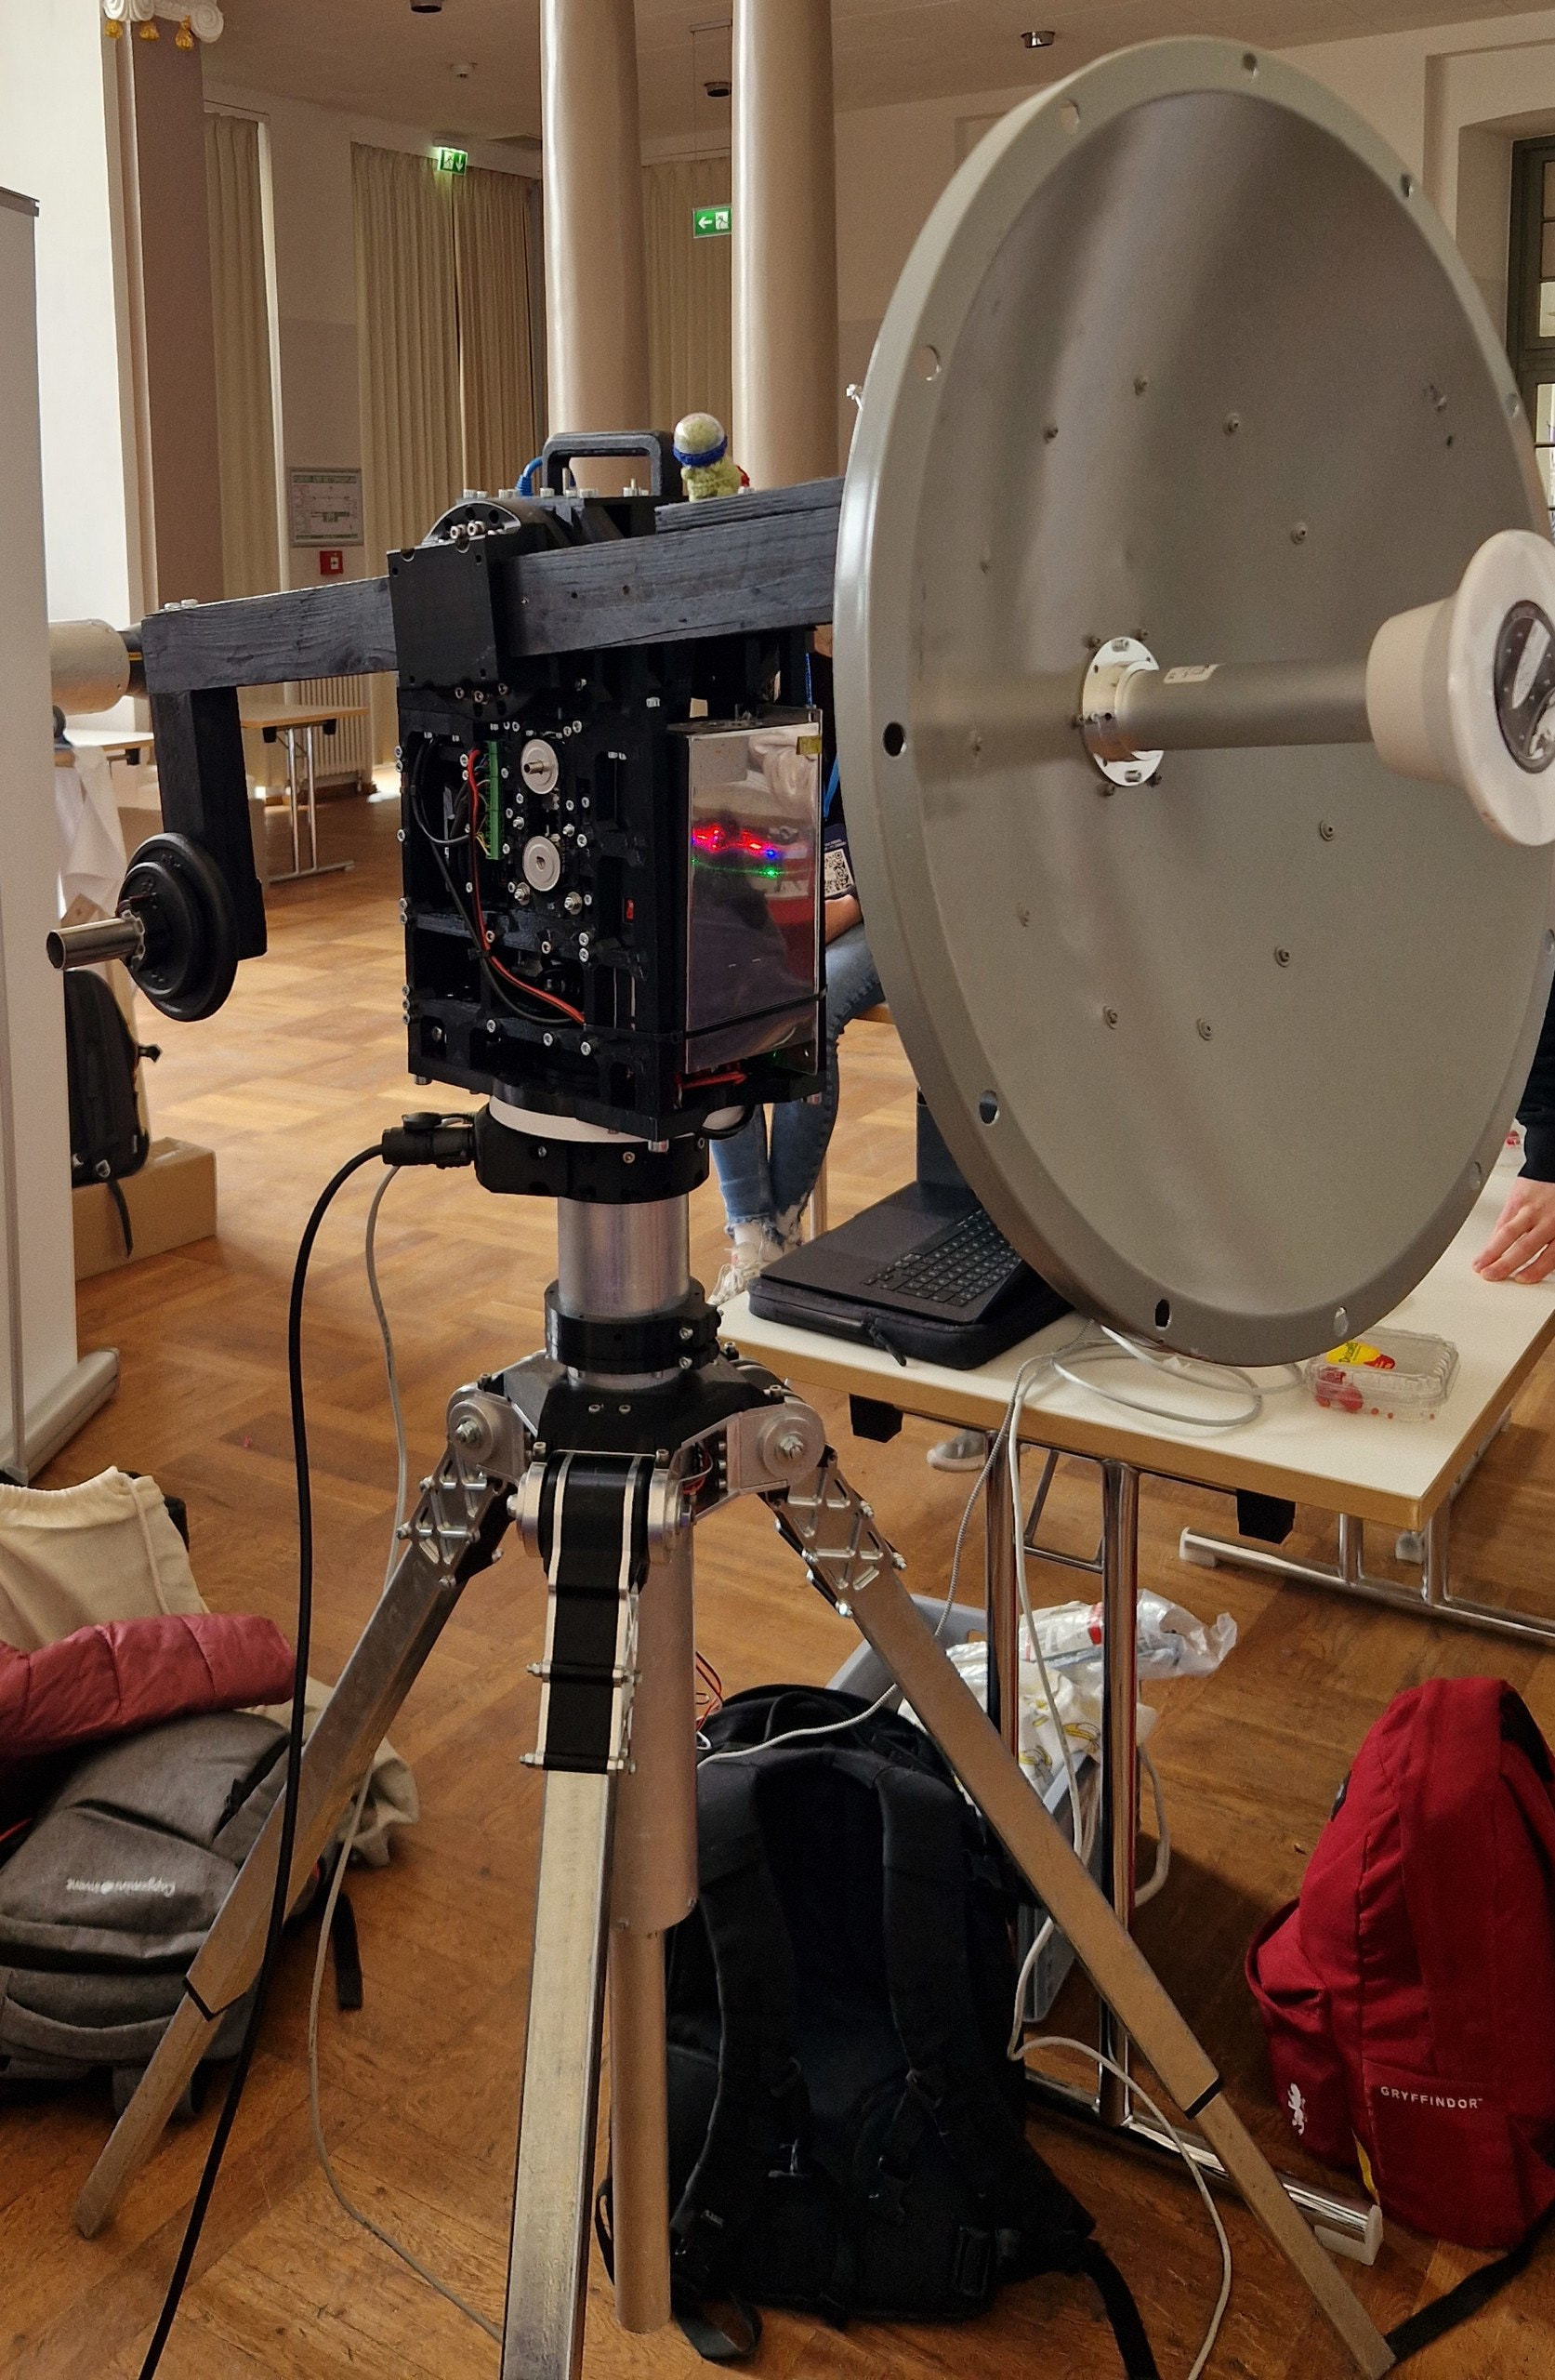
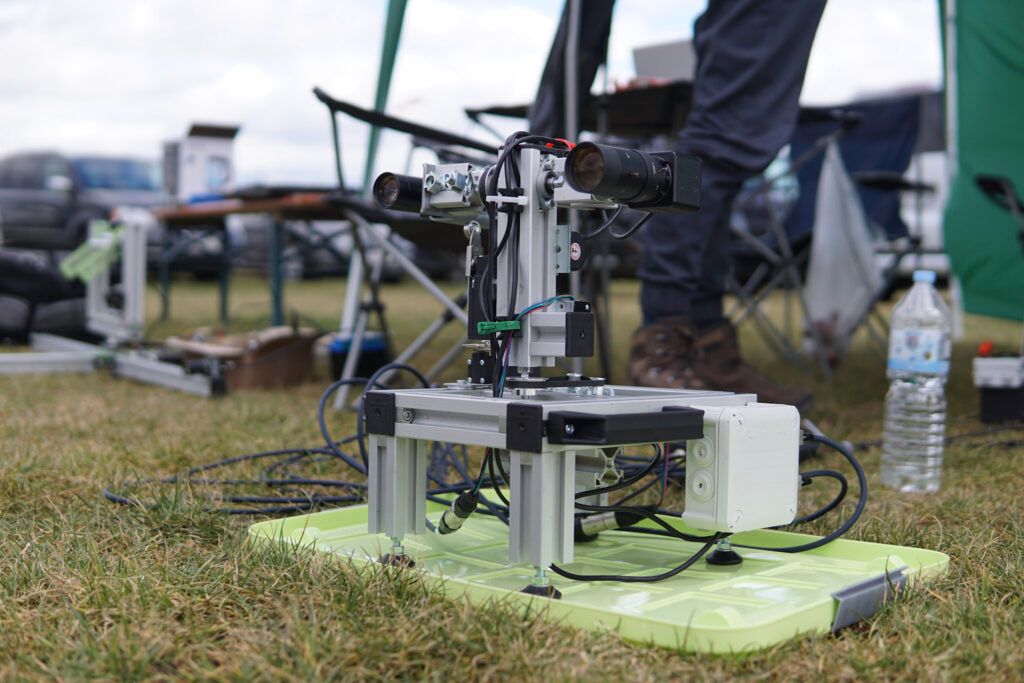
Now on board the rocket we have RocketHD. This is our video transmission system based on the OpenIPC project, an open source fpv tranceiver that leverages standard WiFi hardware to create a long range 5.8GHz link. On the ground side we have our rebuilt T-Rex. It has a 433 MHz Yagi antenna and a 5.8 GHz Dish mounted. The tracker is implemented as a two-axis system with independent horizontal and vertical movement. Both axes are driven by closed-loop NEMA 23 stepper motors. The horizontal axis uses a motor directly connected to a 20:1 gearbox, followed by a 3:1 belt drive, which rotates the tracker and dish antenna in azimuth. The vertical axis uses a NEMA 23 motor connected to a 10:1 gearbox, also followed by a 3:1 belt drive, to actuate the elevation movement.
The belt drives are used to minimize mechanical backlash while maintaining a dynamic and fast-moving system. To improve positioning behavior, the belts are tensioned both statically and dynamically. Final position feedback is provided by Hall effect sensors, allowing the tracker to achieve an approximate repeatable pointing accuracy of 2–3 degrees.
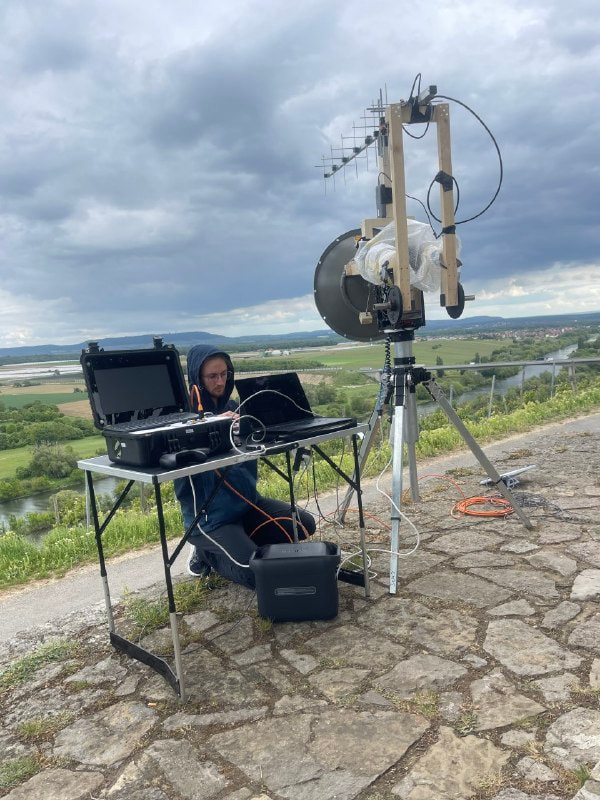
For the control of this tracker we need a processor that can integrate into our ground segment, receive the position of the rocket and be able to point the tracker along the rockets path.
To achieve this we have developed a custom PCB that can connects to the rest of the ground equipment via Ethernet. It receives the newest position estimation and calculates based on that the pose it needs to point to best track the rocket. Using this and the feedback from the internal position sensors ,the board drives the stepper motors hopefully tracking the rocket during our space-shot.
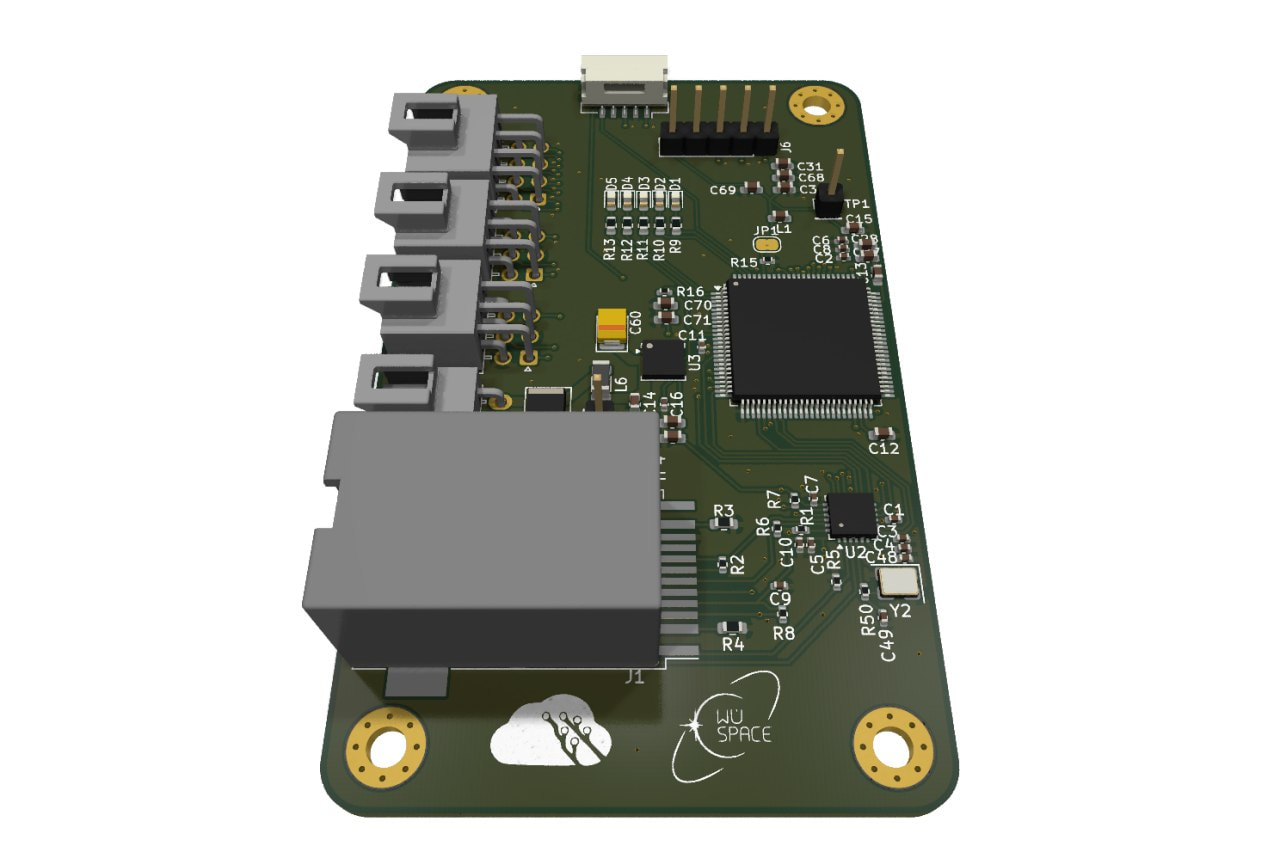
This is our current setup to watch the work of three years fly. We would like to thank AISLER for sponsoring the production of many our PCBs including the T-Rex board.
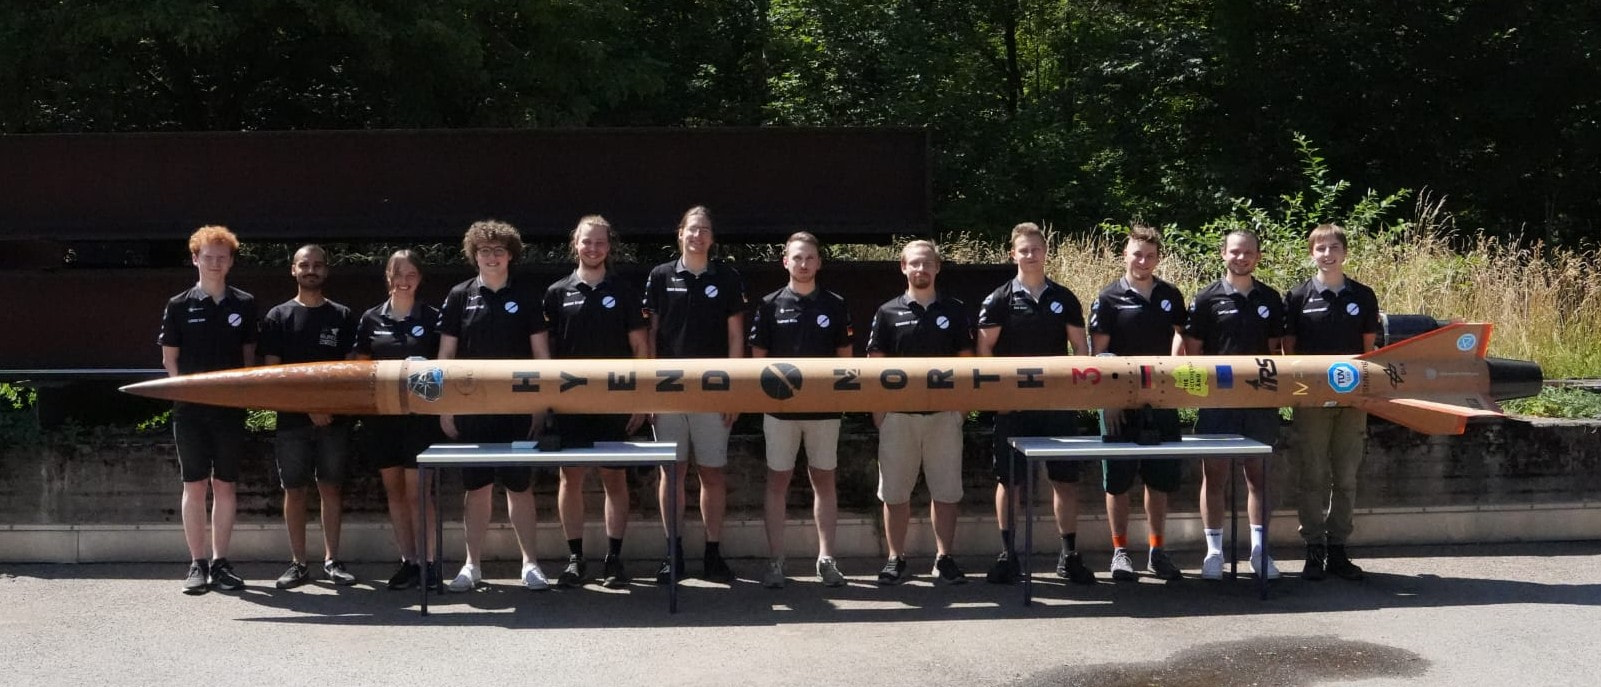
 when is N₂ORTH actually due to go up? And is anyone from the first camera-based version still on the team, or has the project outlasted a couple of ‘generations’ by now?